
Cho một tập hợp các điểm. Ta cần tìm một đường kín đơn giản (simple closed path) đi qua tất cả các điểm.
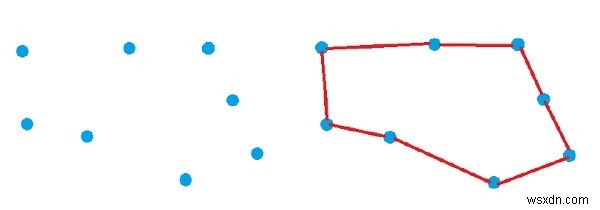
Các bước:
- Tìm điểm góc dưới bên trái làm điểm P.
- Sắp xếp n-1 điểm còn lại theo góc cực (polar angle) theo chiều kim đồng hồ quanh P. Nếu góc bằng nhau thì điểm gần hơn đứng trước.
- Duyệt danh sách đã sắp xếp để tạo đường đi.
Ví dụ
#include <bits/stdc++.h>
using namespace std;

class Point {
public:
    int x, y;
};

Point p0;
int euclid_dist(Point p1, Point p2) {
    return (p1.x - p2.x)*(p1.x - p2.x) + (p1.y - p2.y)*(p1.y - p2.y);
}

int orientation(Point p1, Point p2, Point p3) {
    int val = (p2.y - p1.y) * (p3.x - p2.x) - (p2.x - p1.x) * (p3.y - p2.y);
    if (val == 0) return 0; // thẳng hàng
    return (val > 0)? 1: 2; // kim đồng hồ hoặc ngược
}

int compare(const void *vp1, const void *vp2) {
    Point *p1 = (Point *)vp1;
    Point *p2 = (Point *)vp2;
    int o = orientation(p0, *p1, *p2);
    if (o == 0)
        return (euclid_dist(p0, *p2) >= euclid_dist(p0, *p1))? -1 : 1;
    return (o == 2)? -1: 1;
}

void findClosedPath(Point points[], int n) {
    int y_min = points[0].y, min = 0;
    for (int i = 1; i < n; i++) {
        int y = points[i].y;
        if ((y < y_min) || (y_min == y && points[i].x < points[min].x))
            y_min = points[i].y, min = i;
    }
    swap(points[0], points[min]);
    p0 = points[0];
    qsort(&points[1], n-1, sizeof(Point), compare);
    for (int i=0; i<n; i++)
        cout << "(" << points[i].x << ", " << points[i].y << "), ";
}

int main() {
    Point points[] = {{0, 3}, {1, 1}, {2, 2}, {4, 4},{0, 0}, {1, 2}, {3, 1}, {3, 3}};
    int n = sizeof(points)/sizeof(points[0]);
    findClosedPath(points, n);
}
Kết quả
(0, 0), (3, 1), (1, 1), (2, 2), (3, 3), (4, 4), (1, 2), (0, 3),